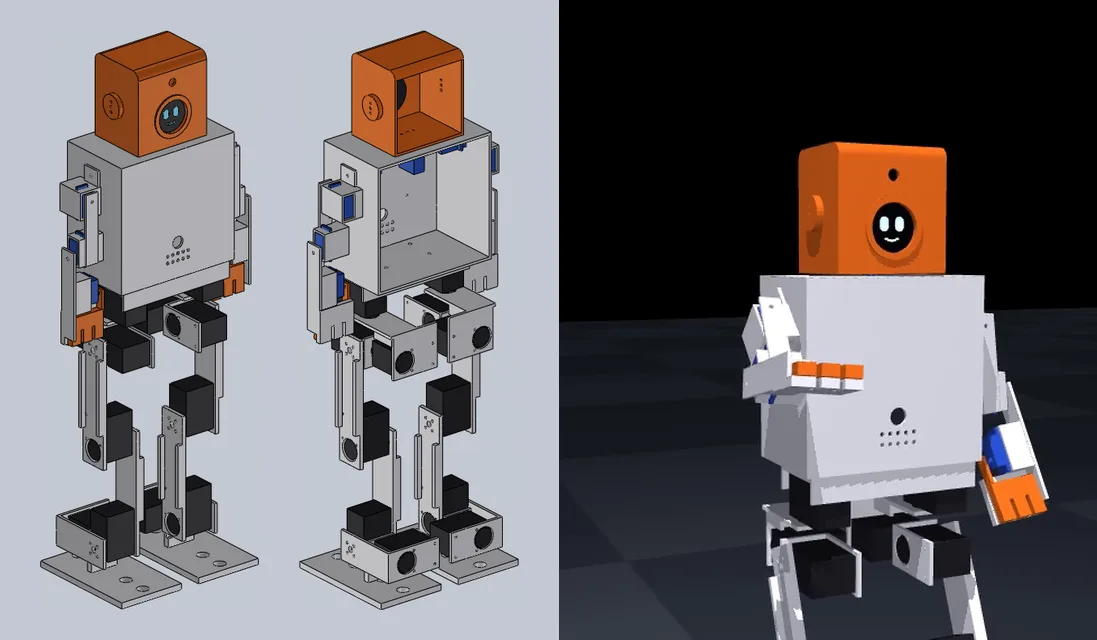
JX0 in SolidWorks, and the simulated robot holding out its gripper hand
About
52 cm tall and printed in PETG, with hobby servos and a Raspberry Pi. It walks, talks, shows a face on a round screen and uses two gripper hands. Same pipeline as JX1: CAD built by script, servo sizing checked, 14 of 14 walking gaits passing in simulation.